SailSwarm: Swarm of Autonomous Sail Boats
A swarm of autonomous sailing robots trialled on Lake Constance — sailing manoeuvres, station keeping and multi-point navigation.
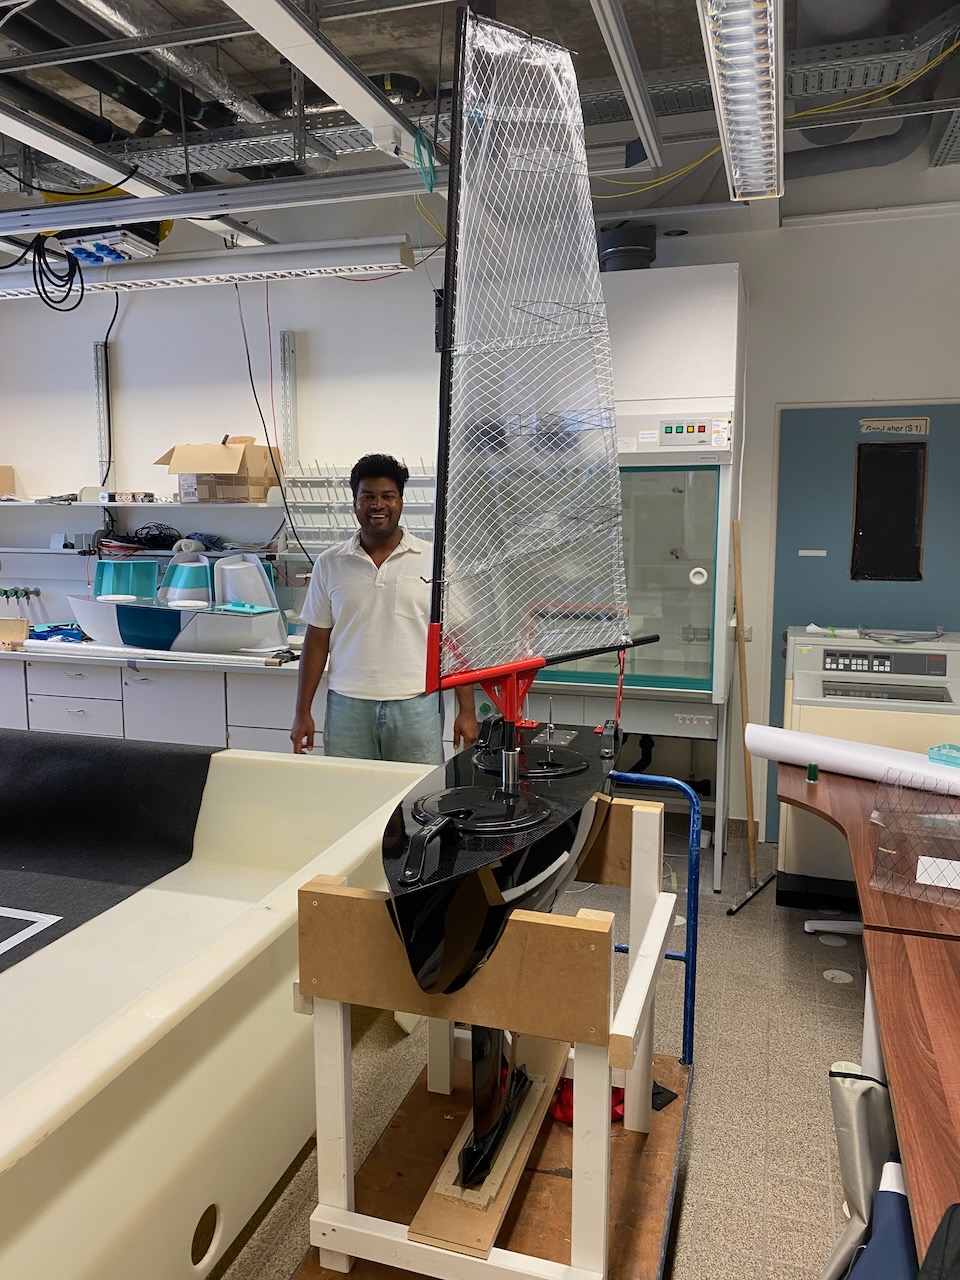
SailSwarm is my PhD project at the University of Konstanz: a swarm of small autonomous sailboats built for long-duration missions on open water. Wind is free and a sailing robot can stay out far longer than a motorised one, but it cannot go wherever it likes, whenever it likes. Getting one boat to sail itself is hard; getting several to sail together is the question this project is about.
Latest from the lake
Two boats, one lake
In September 2026 two of the robotic sailboats went out on Lake Constance together for the first time. For this first multi-robot test both were still running under motor power. The sails come next.
Air, surface and underwater
A joint demo with Hun Jang, Liang Li and Heiko Hamann put three very different robots into one shared environment: an autonomous sailboat on the surface, a robotic fish below it and a quadrotor above. It is an early look at what a swarm spanning several domains could do.
Where this is going
- Now: two robots on the lake, under motor power.
- Next: motors off, sails up, sailing autonomously.
- Then: a swarm on the lake.
More will appear here as it happens.
Earlier trials: a single boat
The first boat, Aqua Flash, learned the basics on its own: sailing manoeuvres, holding a position against the wind, and sailing a course through several points.
Sailing manoeuvres (overhead view)
Station keeping
Multi-point sailing
Papers and tools
- Speed-Weighted Adaptive Flocking for Sailing Swarms under Dynamic Environmental Forcing (SAB 2026)
- Developing SailSwarm: A Swarm of Uncrewed Sailing Vessels for Maritime Environments (IROS 2024 workshop)
- Building SailSwarm: A Swarm of Autonomous Sailing Vessels (ANTS 2024)
- SailSwarmSwIM, the simulator for swarms of sailing robots, and BoatLogExplorer, for inspecting logs from the boats. Both are listed under Tools.
New videos go up on the YouTube channel first.